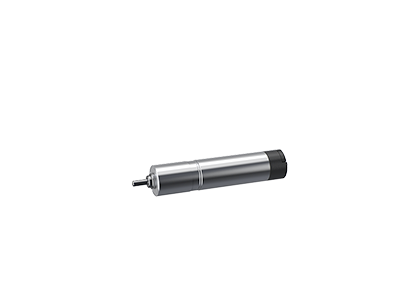
With its ultra-small size, extremely lightweight design, high speed wide speed range, high dyamic response, extremely low rotor inertia, and short mechanical time constant, it can achieve millisecond-level start-stop and speed regulation, meeting the requirements of precision operation.
Data download Back to list
|
Input Voltage |
12V DC |
|
Dimensions(mm) |
Φ35* 8 |
|
Shaft Diameter(mm) |
Ф35 |
|
No load speed(rpm) |
1400 |
|
No load current(A) |
0.04 |
|
Nominal Speed(rpm) |
1100 |
|
Nominal Torque(Nm) |
0.0095 |
|
Nominal Current(A) |
0.3 |
|
Stall Torque(Nm) |
0.045 |
|
Stall Current (A) |
0.96 |
|
Maximum Output Power(W) |
11 |
|
Maximum Efficiency(%) |
42 |
|
Life(Typical) |
/ |
| Weight(g) | 10 |
|
Operating Temperature Range(°C) |
/ |
|
Storage Temperature Range(°C) |
/ |

It is the current consensus of the scientific community that the human body structure is the evolutionary form most adapted to modern civilization. Only humanoid robots are the robot form that is closest to the needs of human daily production and life. Sweeping robots, intelligent speakers, and industrial robotic arms and sorting robots in the industrial field are not intelligent robots. The difference between them and humanoid robots is similar to the difference between a single-function landline telephone and a smartphone. Compared with these so-called robots, humanoid robots are, in short, different in two major ways: a brain that can think and learn independently, and hands that can move flexibly. These two factors, which made man stand out from the animals and become the master of the earth millions of years ago, have also given humanoid robots unlimited possibilities in today's ever-evolving technology.
+
Industrial robot end-effector is an automated equipment component used for precision assembly, handling and other operations in industrial production. It is commonly used in various industrial production scenarios, and is a key component in realizing industrial automation production.As the core component of the industrial robot end-effector, the quality of the motor directly affects the use of the equipment. A good industrial robot end-effector requires motors with the following characteristics: high precision and rigidity, high load and high torque, high reliability and long life.
+Add: Topband Industrial Park, Shiyan, Shenzhen, China.
Fax:0755-27651888-3455E-mail:motor@topband.com.cn
Sign up for our newsletter to receive exclusive deals, industry insights, and company news directly in your inbox!
2019 @ Shenzhen Topband Motor Co.,Ltd. 粤ICP备2022087461号